MultiPLY: A Multisensory Object-Centric
Embodied Large Language Model in 3D World
Yining Hong,
Zishuo Zheng,
Peihao Chen,
Yian Wang,
Junyan Li,
Chuang Gan

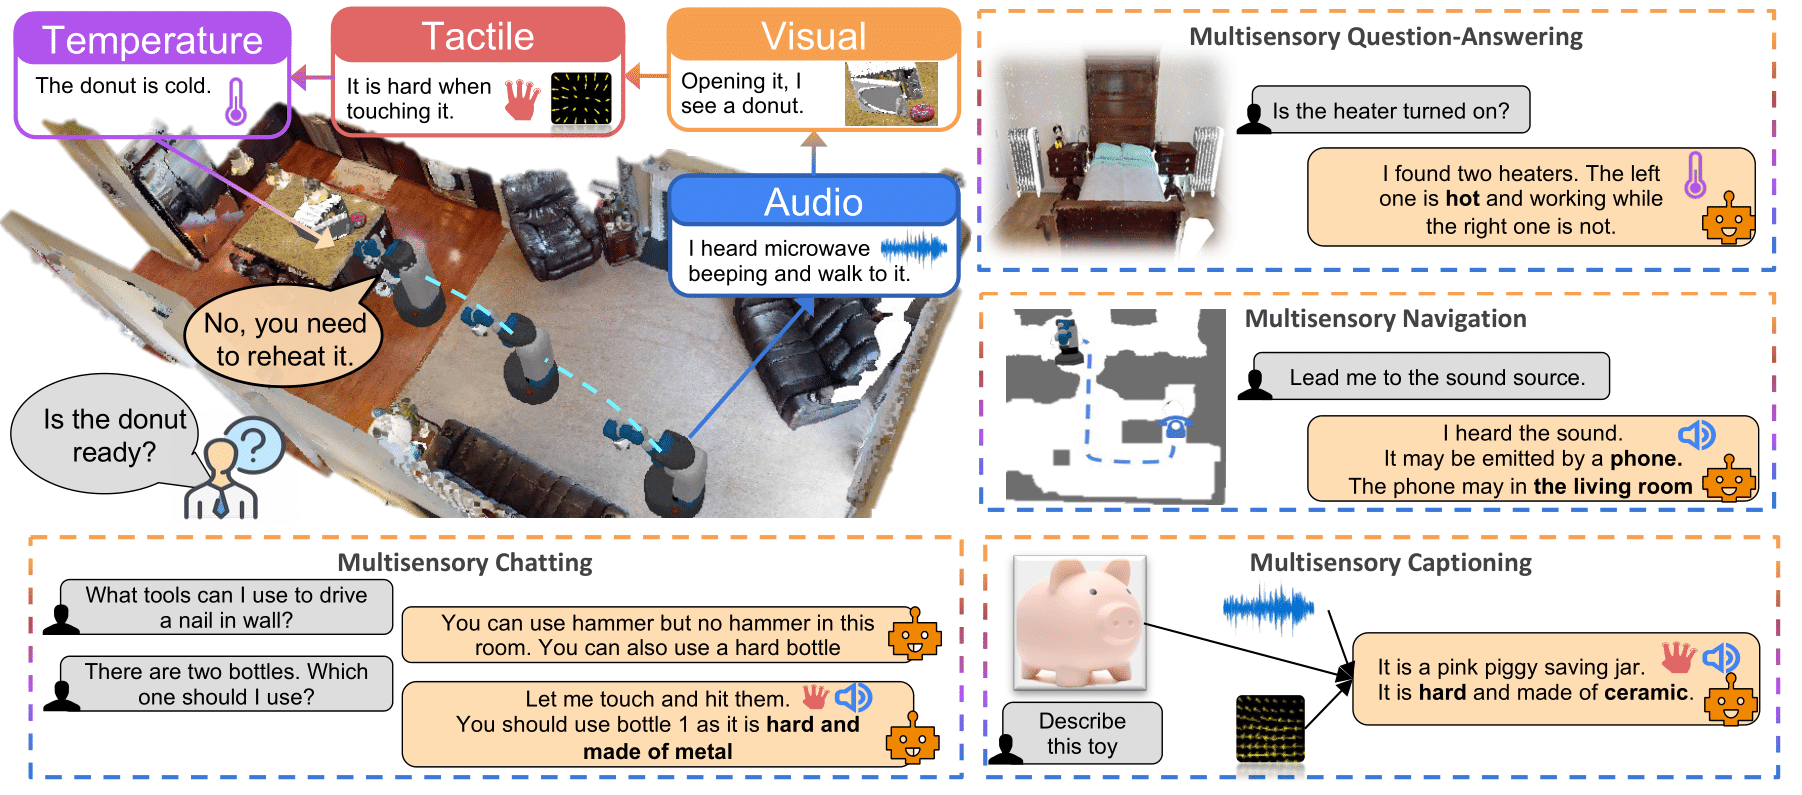
MultiPLY is a multisensory embodied large language model that could actively interact with the objects in the 3D environment and dynamically collect their multisensory information. It could incorporate multisensory interactive data, including visual, audio, tactile, and thermal information into large language models, thereby establishing the correlation among words, actions, and perceptions.
## Method
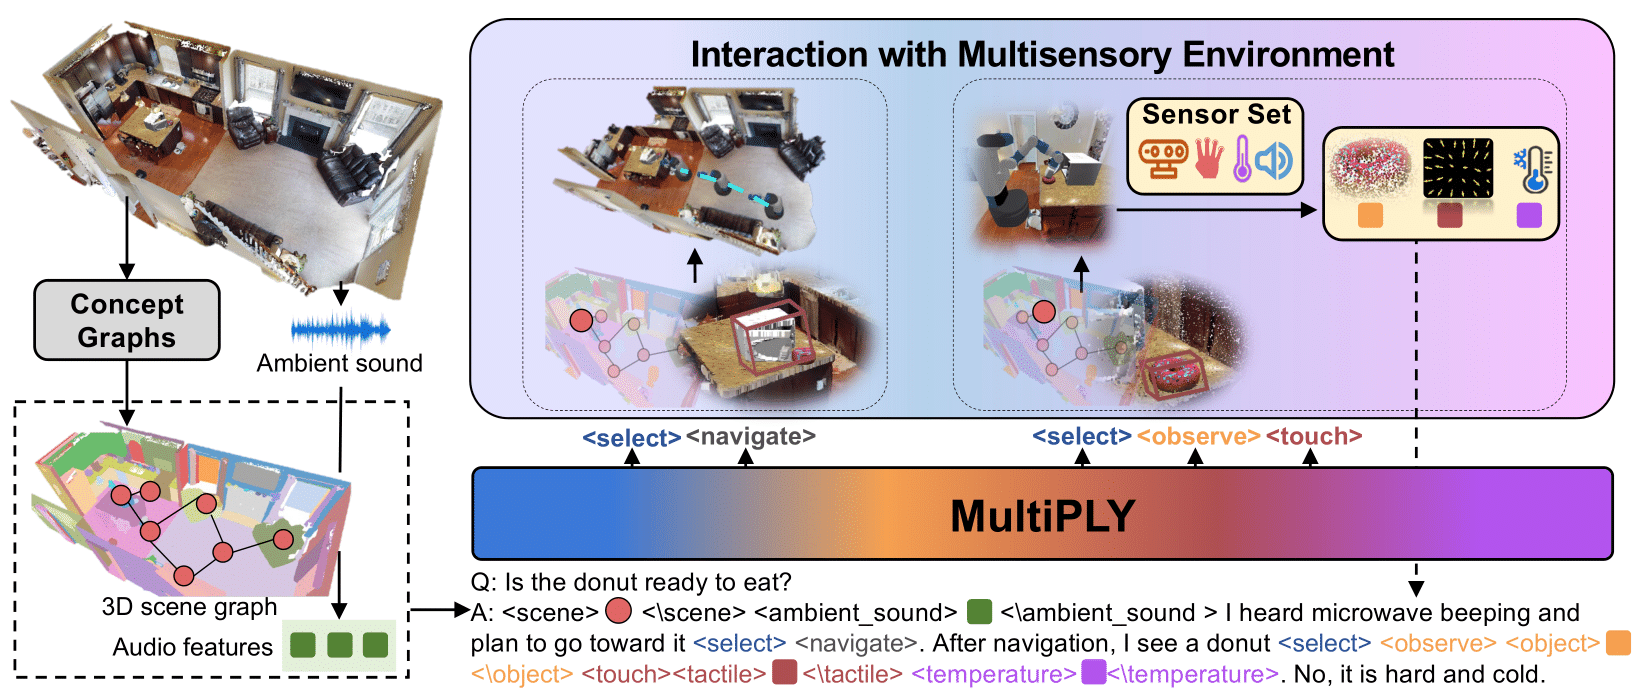
We first encode the scene as an abstracted object-centric representation, while multisensory details
of objects can only be unveiled when the agent executes an action and interacts with them. We devise a set of action tokens denoting the
actions of agents to interact with the environment. The interaction results are appended back to the LLM via state tokens
## Requirements
TODO
## Training
We use FSDP training. It might differ on different clusters. An example on the trained cluster is:
```
RANDOM=$$
DIV=1000
OFFSET=24000
MASTER_PORT=$(($RANDOM%$DIV+$OFFSET))
export OMP_NUM_THREADS=1
export TOKENIZERS_PARALLELISM=true
NODE_RANK=${SLURM_PROCID}
SLURM=${SLURM_NODELIST:0:3}
ip=${SLURM}${SLURM_NODELIST:4:2}
# run the training script
NUM_GPUS_PER_NODE=${1:-8}
echo $NUM_GPUS_PER_NODE
NUM_NODES=${2:-1}
CMD="torchrun --nnodes=$NUM_NODES --nproc_per_node=$NUM_GPUS_PER_NODE --master_addr=$ip --node_rank=$NODE_RANK"
$CMD \
fsdp_train.py --folder retrieval_attention3 --num_epochs=1000
```
## Dataset Curation
TODO
## Citation
```
@article{multiply,
author = {Hong, Yining and Zheng, Zishuo and Chen, Peihao and Wang, Yian and Li, Junyan and Chen, Zhenfang and Gan, Chuang},
title = {MultiPLY: A Multisensory Object-Centric Embodied Large Language Model in 3D World},
journal = {arXiv},
year = {2024},
}
```